UAV design
Design and development of a surveillance drone
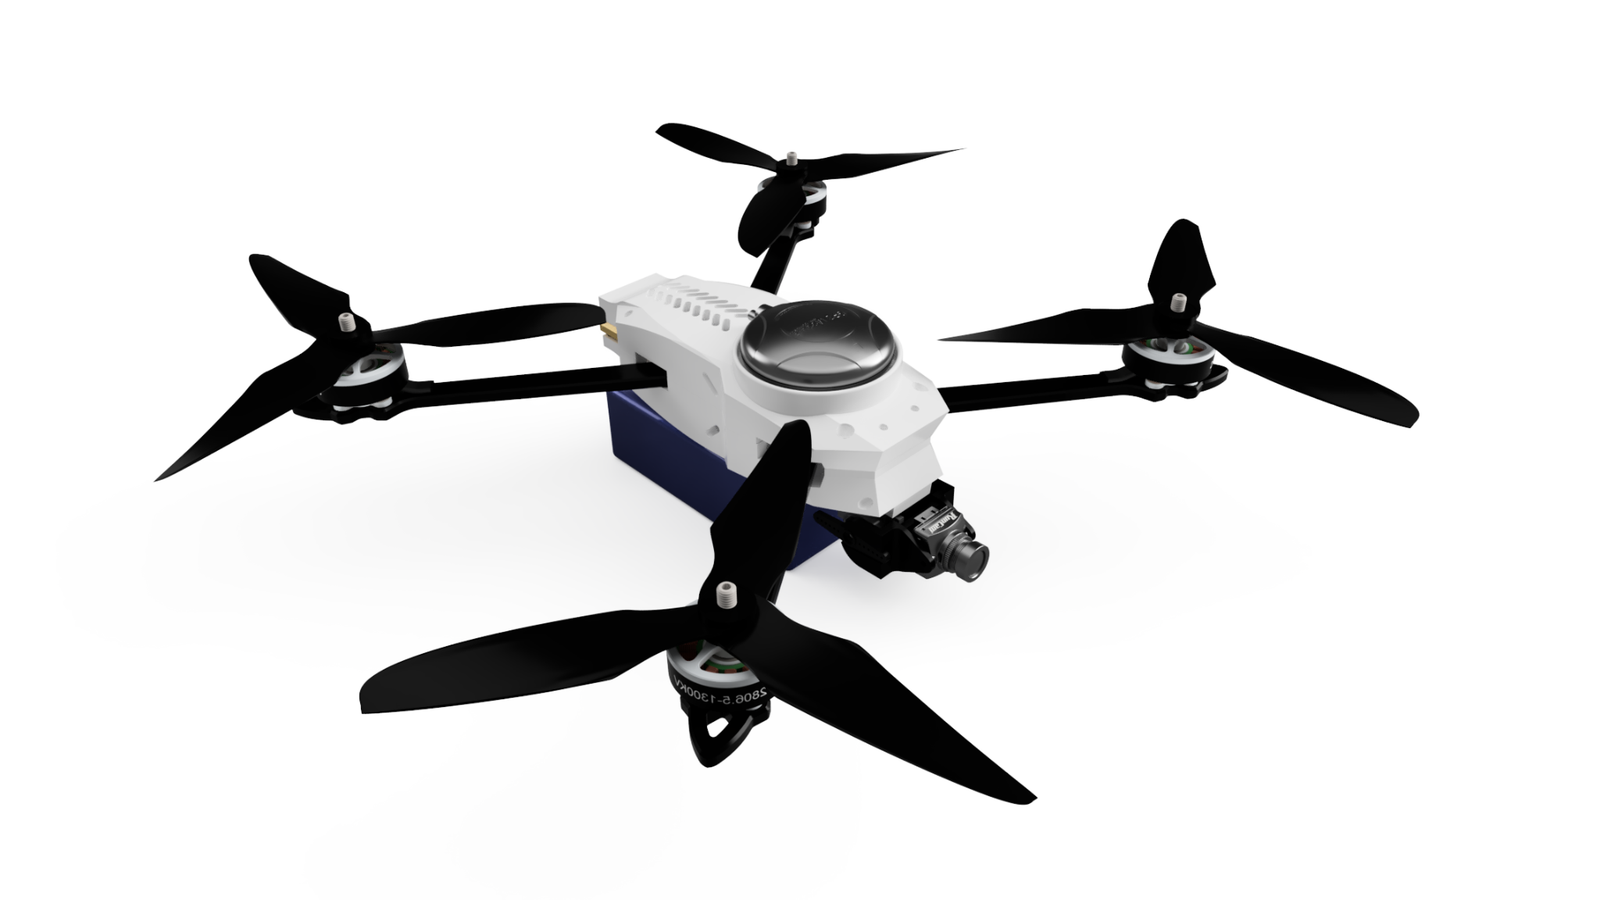
A quadcopter for live aerial monitoring, with GPS waypoint navigation and an FPV camera link, balanced around its centre of gravity.
The requirement
The problem this answered.
Real-time aerial monitoring needs stable flight, reliable positioning and a video link that stays usable at range, and all three compete for the same weight allowance.
Constraints and operating environment: Outdoor flight with live downlink to a ground station.
Vebix scope
What we did.
We designed a quadcopter for live aerial monitoring and inspection, with brushless motors, ESCs, a flight controller, GPS position tracking and waypoint navigation.
An FPV camera sends live video to the ground station. We placed the battery, camera and telemetry radio to keep the centre of gravity right, then tested stability, control response, video quality, interference, latency and vibration.
- Discipline
- UAV design and integration
- Navigation
- GPS position tracking and waypoints
- Payload
- FPV camera with live downlink
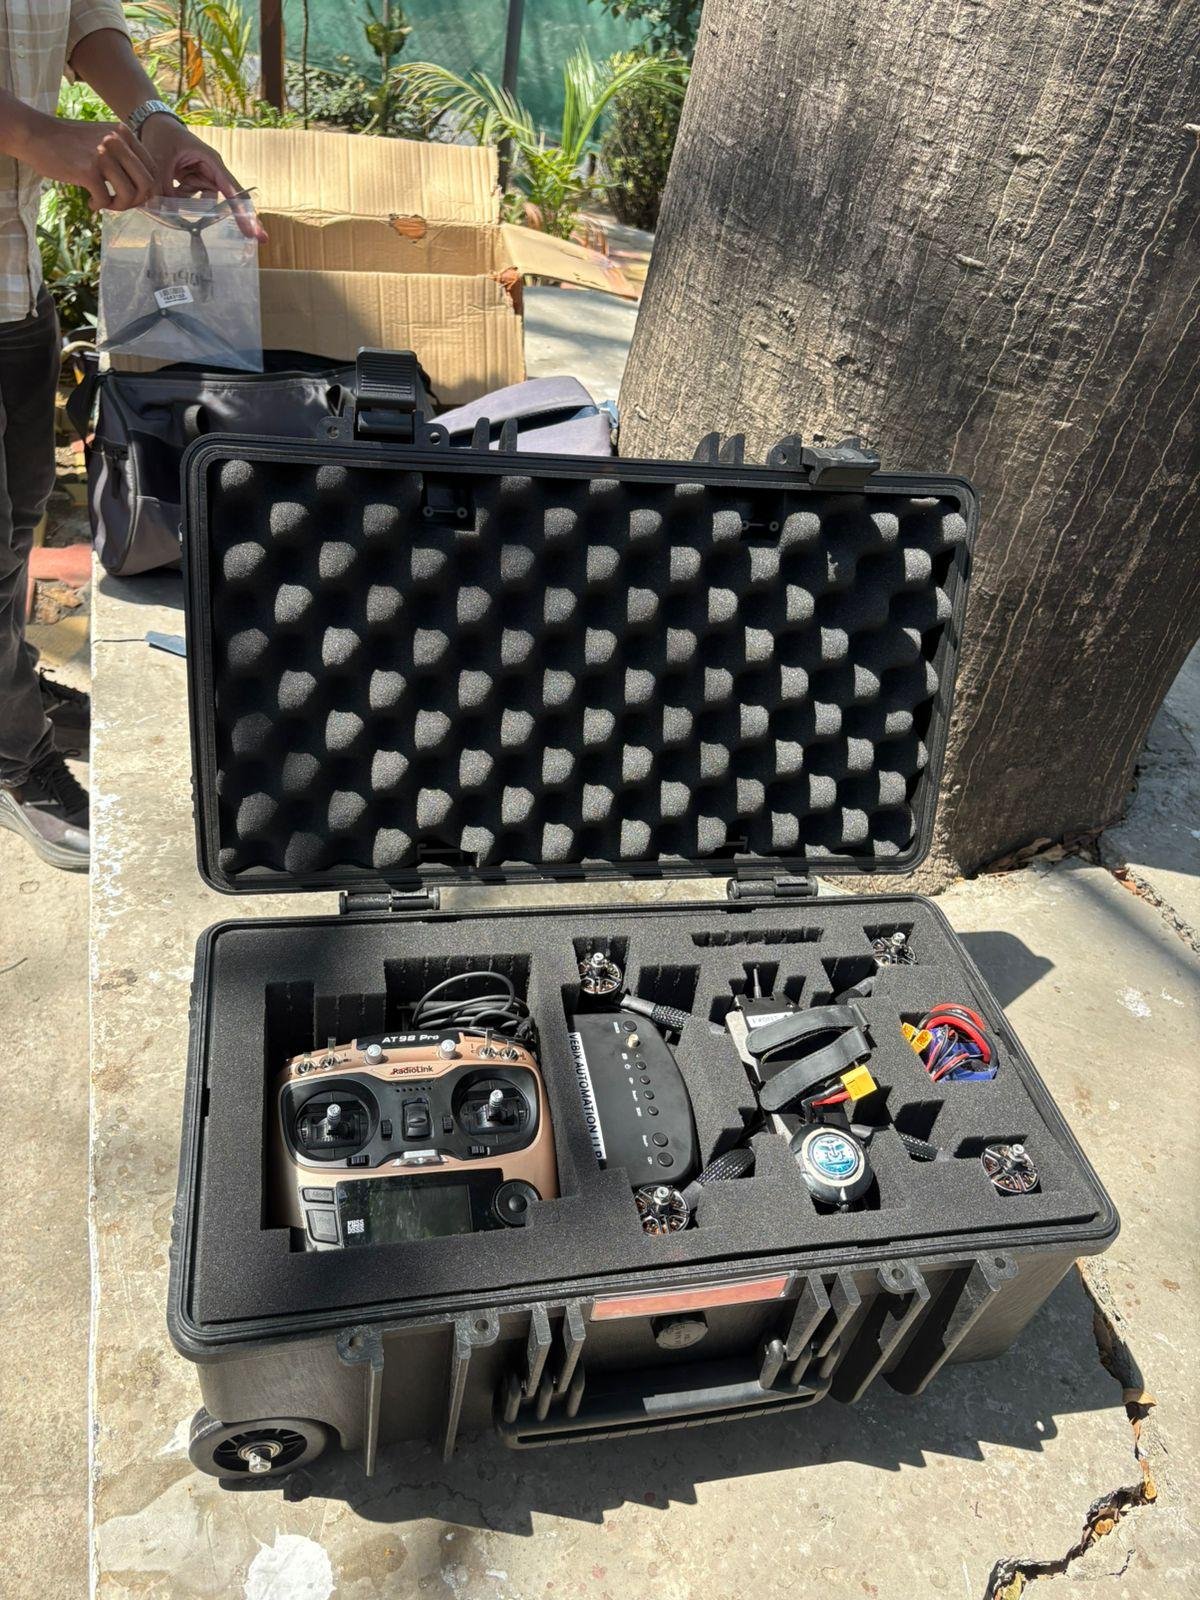
Project visuals
From the build.
Related
The services and components behind this work.
More work
Other projects.
Related work from our portfolio of robotics, unmanned platforms, cable assemblies, data acquisition and mechanical design.
Request a quotation
Tell us about the work.
Send the scope, the environment it has to work in and your timeline. We reply within one working day.
Discuss a similar projectSee all services
Or call +91 97028 20020.