Robotics
Design and development of a 6-axis industrial robotic arm
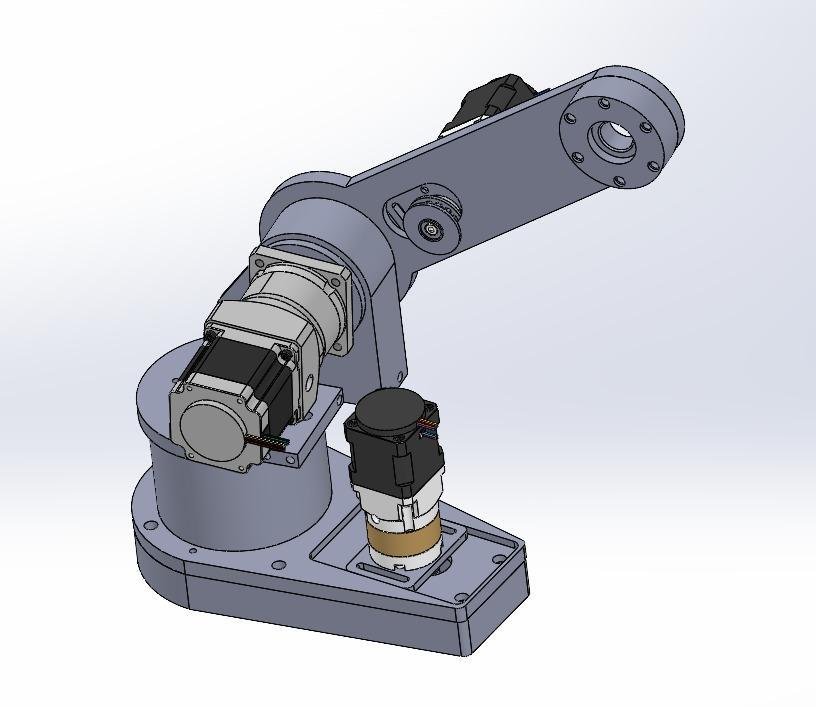
Mechanical design of a six-axis industrial robotic arm: joint torque, payload and reach, with the servos, encoders and control electronics fitted.
The requirement
The problem this answered.
A six-axis arm for controlled industrial motion, where joint torque, payload and reach had to be settled together against what could be manufactured and bought.
Constraints and operating environment: Industrial, repeatable positioning duty.
Vebix scope
What we did.
We designed the mechanics of a six-axis robotic arm, working joint torque, payload and reach out together so the structure would stay stiff and precise in controlled industrial motion.
We fitted the servo motors, encoders and control electronics to the chassis, had the precision parts made or bought them in, and tested the structural locking mechanisms. The design was adjusted to suit the materials we could get and the processes available to make it.
- Discipline
- Mechanical design and integration
- Axes
- Six
- Scope
- Design, fabrication and procurement
Project visuals
From the build.
More work
Other projects.
Related work from our portfolio of robotics, unmanned platforms, cable assemblies, data acquisition and mechanical design.
Request a quotation
Tell us about the work.
Send the scope, the environment it has to work in and your timeline. We reply within one working day.
Discuss a similar projectSee all services
Or call +91 97028 20020.