Robotics
Design and development of an exoskeleton
Control software for an upper-limb assistive exoskeleton, tested in MATLAB simulation before hardware and sensor-based control are added.
The requirement
The problem this answered.
An assistive exoskeleton's control logic has to be right before any hardware moves against a person's arm, so we checked the kinematics in simulation first.
Constraints and operating environment: Upper-limb assistive use; development ongoing.
Vebix scope
What we did.
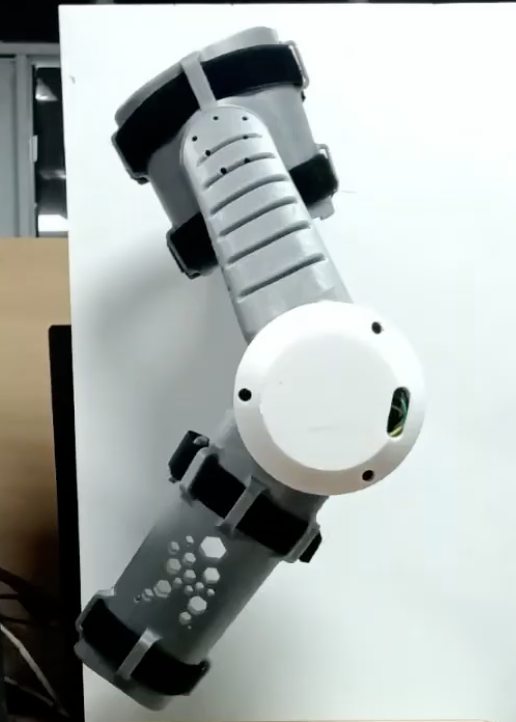
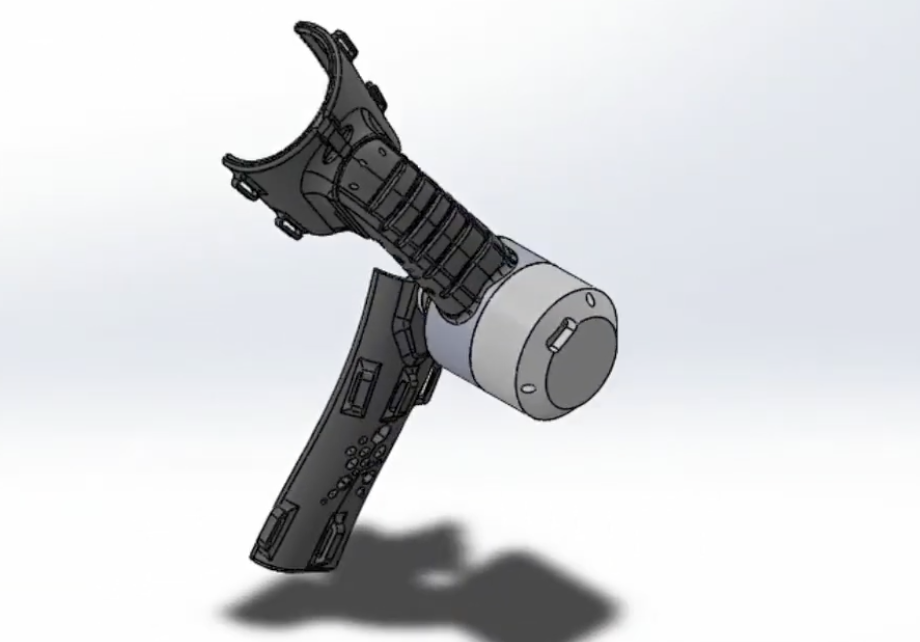
This is an ongoing project to develop the control system for an upper-limb assistive exoskeleton. We use MATLAB to generate joint movement commands, test the control logic and check the kinematics before any hardware is fitted.
Live visualisation shows how the joints respond and how accurate the control is. The next stages are fitting the hardware and adding sensor-based control, possibly using EMG signals to read what the wearer intends and adapt to it.
- Discipline
- Assistive robotics
- Status
- Ongoing
- Validation
- MATLAB kinematic and control simulation
Project visuals
From the build.
More work
Other projects.
Related work from our portfolio of robotics, unmanned platforms, cable assemblies, data acquisition and mechanical design.
Request a quotation
Tell us about the work.
Send the scope, the environment it has to work in and your timeline. We reply within one working day.
Discuss a similar projectSee all services
Or call +91 97028 20020.