Robotics
Design and development of a 6-DoF robotic arm with vehicle
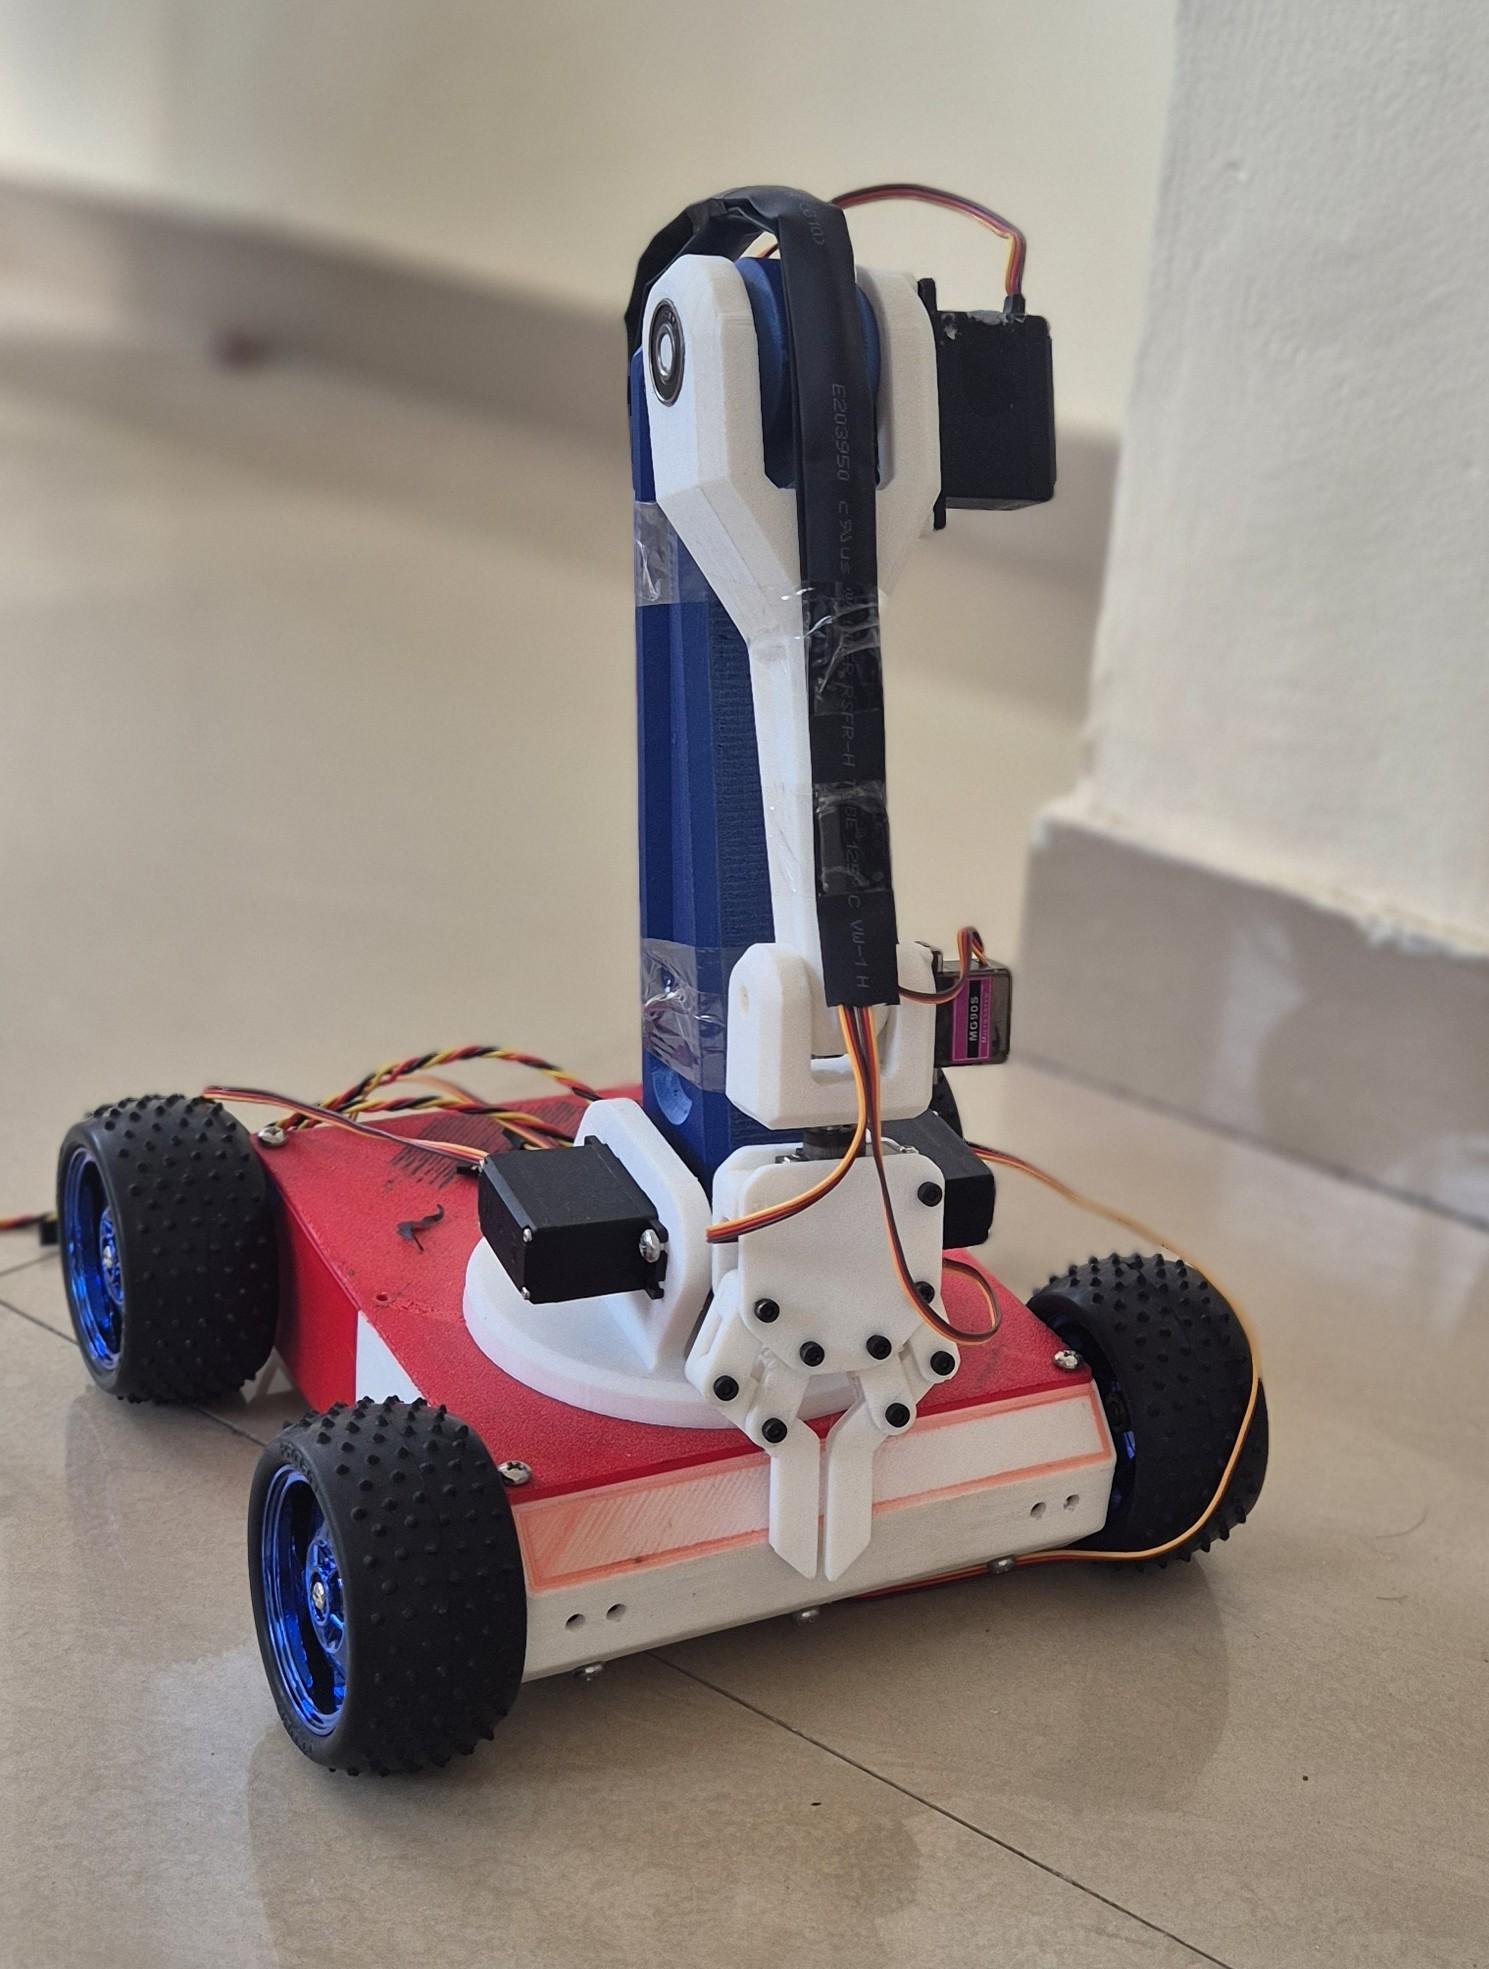
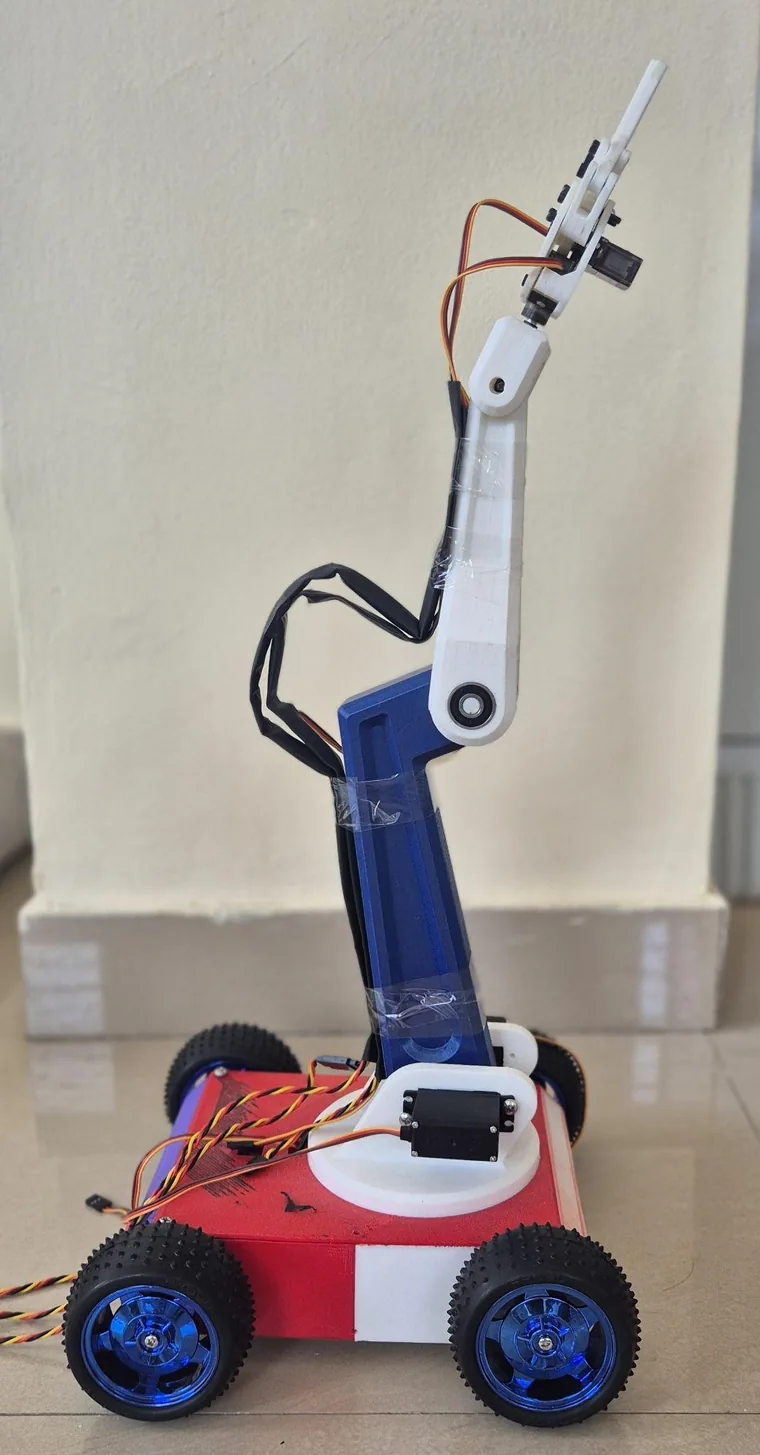
A six-axis robotic arm on a mobile platform, driven with the vehicle from one MATLAB App Designer panel that sets each joint angle in real time.
Mechanics, control and the operator
Six joints, commanded as one system.
A six-axis robotic arm on a mobile platform, driven with the vehicle from one MATLAB App Designer panel that sets each joint angle in real time.
- DisciplineRobotics and control
- Degrees of freedomSix
- Control interfaceMATLAB App Designer
The requirement
The problem this answered.
On a moving platform, the arm and the vehicle have to be driven as one system, and the operator needs to adjust joint angles while watching the result, without editing code between attempts.
Constraints and operating environment: Mobile platform, six-axis arm, operator in the loop.
Vebix scope
What we did.
We built a six-degree-of-freedom arm for precise handling tasks on a mobile platform. The work centred on controlling the arm in real time and making it work together with the vehicle it rides on.
A MATLAB App Designer panel lets the operator set each joint angle and watch the arm respond straight away. Nobody has to type code during operation, which makes the system much easier to use.
- Discipline
- Robotics and control
- Degrees of freedom
- Six
- Control interface
- MATLAB App Designer
Project visuals
From the build.
Related
The services and components behind this work.
More work
Other projects.
Related work from our portfolio of robotics, unmanned platforms, cable assemblies, data acquisition and mechanical design.
Request a quotation
Tell us about the work.
Send the scope, the environment it has to work in and your timeline. We reply within one working day.
Discuss a similar projectSee all services
Or call +91 97028 20020.